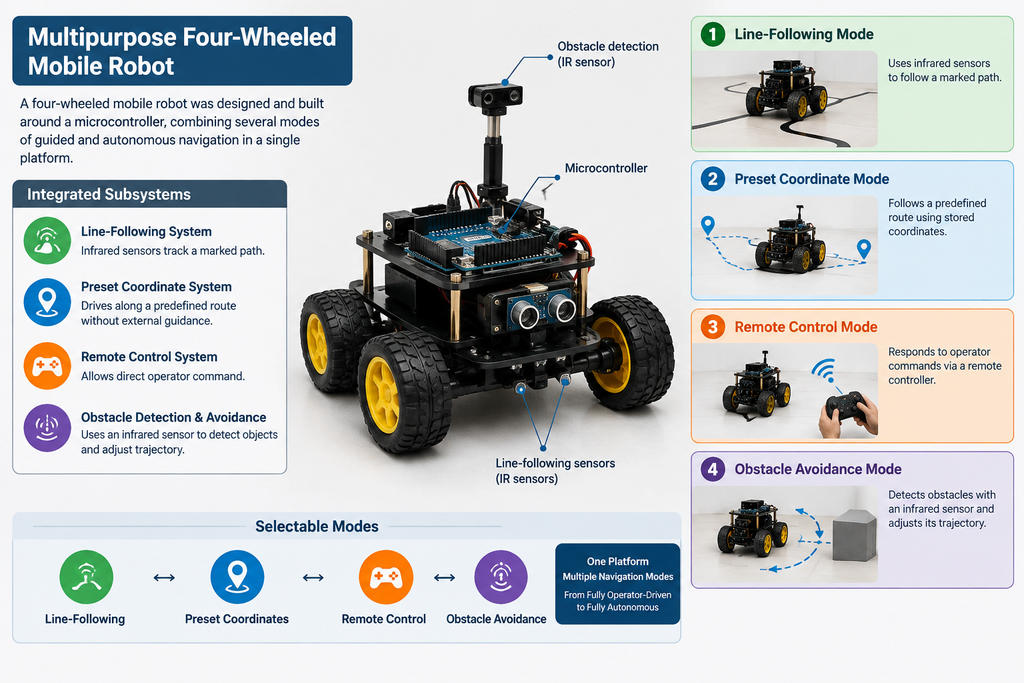
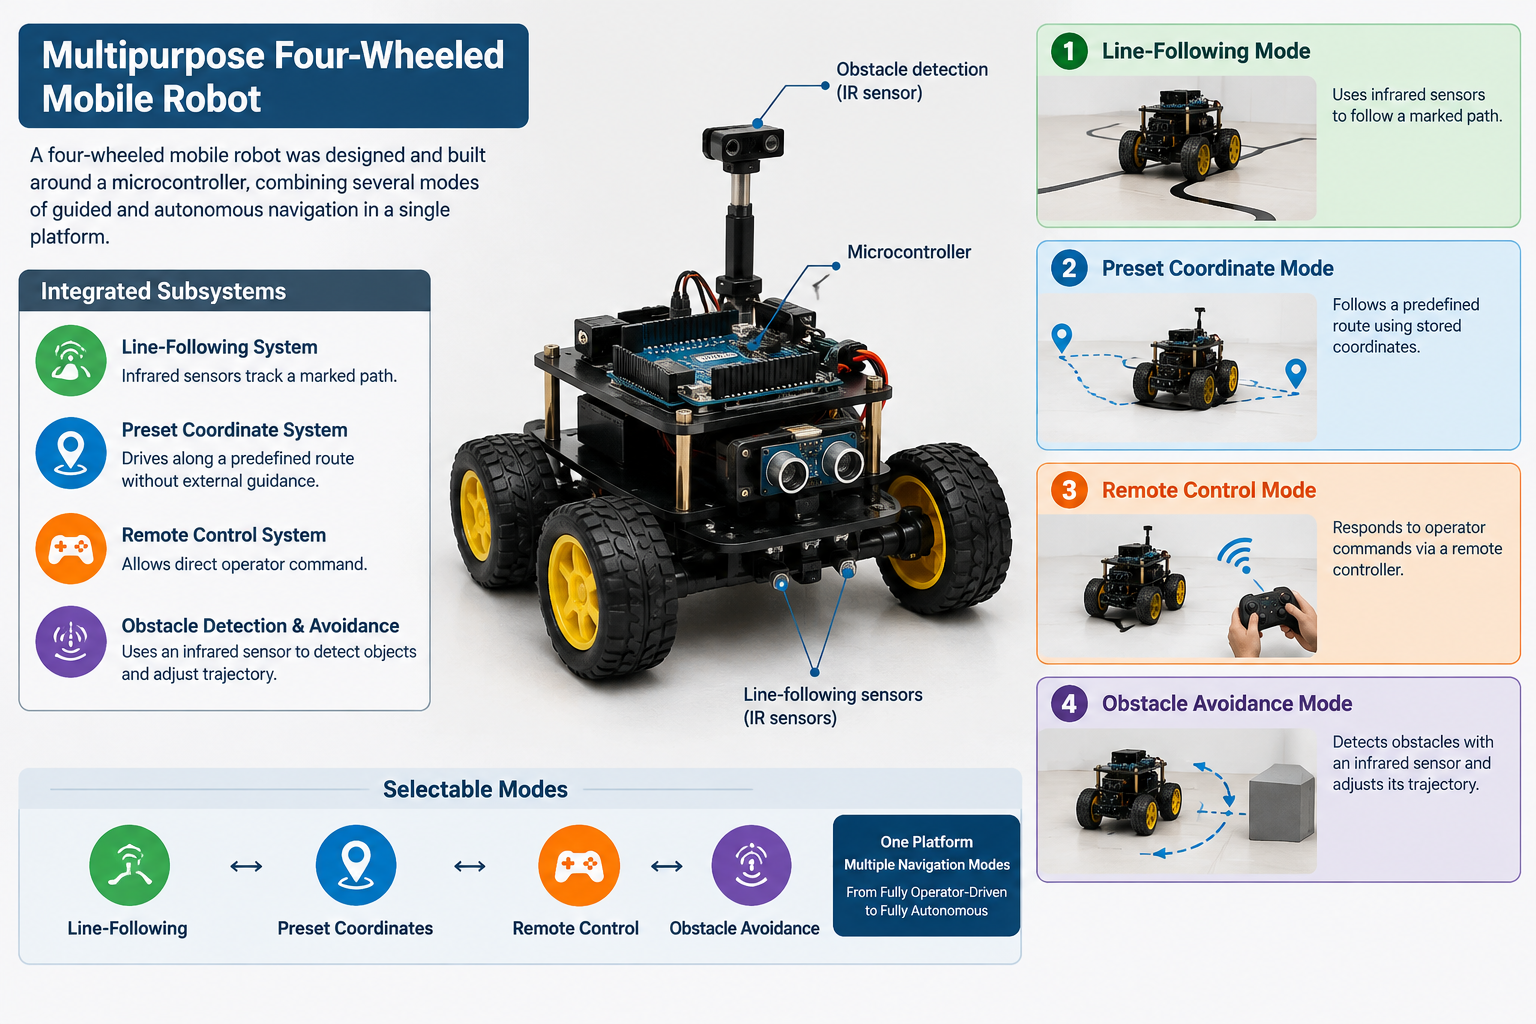
A multipurpose four-wheeled mobile robot was designed and built around a microcontroller, combining several modes of guided and autonomous navigation in a single platform. Four subsystems were integrated: a line-following system using infrared sensors to track a marked path, a preset coordinate-based movement system that drove the robot along a predefined route without external guidance, a remote control system allowing direct operator command, and an obstacle detection and avoidance system using an infrared sensor to detect objects in the robot’s path and adjust its trajectory to clear them. The modes were selectable independently, allowing the same platform to serve navigation tasks ranging from fully operator-driven to fully autonomous.